Allen-Bradley 2097-V34PR6 Kinetix 300 Servo Drive 3.0 kW – Pickup in Store
In stock: 2 units in Milwaukee, WI. Physically stocked and ready to ship or available for local pickup. Includes a 1-year full-function warranty.
Kinetix 300 3.0 kW servo drive · 480V AC three-phase input · 8.5 A continuous output (0-pk) · EtherNet/IP indexing drive with built-in motion profiles · Safe Torque-Off

Actual NJT inventory photos
Price
$4,249.99USDUsed, Series AView listing
| Part Number | 2097-V34PR6 |
| Description | Kinetix 300 servo drive, 3.0 kW, 480V AC. In stock in used condition, Series A. |
| Shipping | Ships same or next business day
|
| Pickup | Free local pickup at 2122 N Prospect Ave. Call ahead at (414) 331-5954. |
| Warranty | 1-year full-function warranty provided by NJT Automation. Warranty details
|
| Returns | 90-day free returns. View return policy |
| Exchange | Send us your defective 2097-V34PR6 after your purchase for a 10% core credit. We also purchase old or damaged parts outright. |
Replacement Options for 2097-V34PR6


| Variants | Part NumberConditionSeriesQtyPrice 2097-V34PR6 /A$4,249.99 Used · Series A · 2 in stock2097-V34PR6 /AUsedSeries A2$4,249.99 USD Looking for the Kinetix 350 (-LM)? 2097-V34PR6-LM has 10 in stock. | ||||||||||||||||||||||||||
| Availability | 2 units in stock | ||||||||||||||||||||||||||
| Repairs | 2097-V34PR6 Mail-In Repair Service | Flat RateFlat rate: $2,049.99 | ||||||||||||||||||||||||||
Part Number Decoder | Kinetix 300 servo drive 2097V34PR6
Decoded from the Rockwell Automation catalog-number structure. Series and firmware revision are printed on the product label, not encoded here. | ||||||||||||||||||||||||||
Series & Revisions | Series A in stock; other series on request. | ||||||||||||||||||||||||||
Intended Use | Intended for single-axis indexing and positioning applications. Kinetix 300 drives run one servo axis as a standalone indexer configured from a web browser and commanded over EtherNet/IP, Modbus or discrete I/O, on labelers, feeders, cut-to-length, conveyors and small positioning tasks that do not need a full motion controller. Safe Torque Off lets the drive sit in the machine's safety circuit without an external contactor. | ||||||||||||||||||||||||||
Migration Path | Rockwell Automation has discontinued the Kinetix 300. Published successor for the Kinetix 300: Kinetix 5100 (2198-E), Rockwell's current standalone indexing servo drive.
A like-for-like replacement or a repair keeps the existing program, wiring and panel layout; a migration is a project. Both are listed on this page so the choice can be made on lead time and budget. | ||||||||||||||||||||||||||
Physical Data | Weight and DimensionsWeight3.97 lb (1.80 kg)H × W × D9.1 × 2.7 × 7.2 in. (230 × 68 × 182 mm)
Product weight and dimensions are typical manufacturer-published values and may differ by series or option. Shipping box and weight are estimates for freight planning; the packed unit may ship in a different box. | ||||||||||||||||||||||||||
Similar Part Numbers |
| ||||||||||||||||||||||||||
Allen Bradley Information | Technical Specifications12 parameters from manufacturer-published specifications
Typical manufacturer-published values for this catalog number; confirm against the current manufacturer documentation before specifying. | ||||||||||||||||||||||||||
| Category | Kinetix 300 | ||||||||||||||||||||||||||
| UPC / GTIN | 884951147591 | ||||||||||||||||||||||||||
| Part Number | 2097-V34PR6 | ||||||||||||||||||||||||||
| Manufacturer | Allen-Bradley | ||||||||||||||||||||||||||
Previously sold 2097-V34PR611 sold · +9 on eBay
NJT Automation has supplied and shipped 11 2097-V34PR6 Kinetix 300 servo drives since 2024; these listings are sold and the in-stock options above are ready to ship.
- Sold
- 11 since 2024
- Series
- A × 9


Image gallery115 PHOTOSActual units photographed by NJT
Can the 2097-V34PR6 be repaired?
Yes. NJT Automation repairs the 2097-V34PR6 by mail-in: diagnostic evaluation, component-level repair and a functional test, backed by a 1-year full-function warranty.
Option 1
NJT managed repair
- Evaluation
- Free. No repair, no charge.
- Shipping
- Prepaid UPS label both ways.
- Pricing
- $650 minimum. Rush service available.
- Warranty
- 1-year full-function warranty included; 2- and 3-year options.
Option 2
Independent repair bids. Compare quotes from independent repair technicians. Post your repair on RepairMode to receive competitive bids from experienced technicians. Each technician sets their own pricing and warranty.
Common Failures
Failure patterns we regularly see on Kinetix 300 servo drive hardware like the 2097-V34PR6:
- Current sensor (Hall-effect) drift: torque ripple, motor hum at enable, or false overcurrent trips
- EtherNet/IP port failure: PHY or magnetics damaged by a surge, drive drops off the network or the MotionView web interface is unreachable
- Encoder communication faults (E30 / E31) with intelligent (Hiperface / Stegmann) feedback: feedback board serial channel
- Feedback lost / illegal Hall state (E07 / E11) that follows the drive: failed encoder interface or the encoder 5V supply on the control board
- Precharge resistor or relay failure: the DC bus never charges and the drive will not enable
Fault code reference
2097-V34PR6 Fault Codes
29 codes · 2097-UM001
Fault codes a Kinetix 300 servo drive reports on the drive's front-panel status display (E followed by two digits), as documented in Rockwell Automation publication 2097-UM001. Use them to narrow a problem down to the unit, its wiring or the application before sending it in for repair.
| Code | Fault | What it indicates |
|---|---|---|
| E04 | Motor overtemperature | The motor thermostat or thermistor tripped: high ambient, excessive current, wiring error or wrong motor selection. |
| E06 | Hardware overtravel | The axis moved beyond the physical travel limit input. |
| E07 | Feedback lost | Motor feedback wiring is open, shorted or missing. |
| E09 | Bus undervoltage | DC bus voltage dropped below limit with power applied; check incoming AC and the drive enable sequence. |
| E10 | Bus overvoltage | DC bus voltage above limit, usually excessive regeneration; add or check the shunt resistor. |
| E11 | Illegal Hall state | Hall feedback inputs are in an invalid state; check motor feedback wiring. |
| E12 | Home search failed | The homing sequence did not complete. |
| E14 | Ethernet I/O connection lost | The EtherNet/IP I/O connection to the controller dropped. |
| E16 | Software overtravel | The axis exceeded a software position limit. |
| E18 | Overspeed | Motor speed exceeded 125% of maximum rated speed. |
Show 19 more codes
| E19 | Excess position error | Following error exceeded the position error limit. |
| E23 | Drive thermal protection | The drive thermal model indicates its continuous rating has been exceeded. |
| E26 | Index parameter out of range | An indexing parameter is outside the allowed range. |
| E27 | Absolute move fault | An absolute move was commanded before the axis was homed. |
| E30 | Encoder communication fault | Communication was not established with the intelligent (serial) encoder. |
| E31 | Encoder data corrupted | The data read from the motor encoder failed its integrity check. |
| E39 | Safe Torque Off while enabled | The STO input opened while the drive was enabled. |
| E43 | Drive enable input | The hardware enable input was removed, or enable was attempted without it. |
| E44 | Controller changed to PROG mode | The Logix controller was switched to Program mode while the drive was running. |
| E67 | Operating system failed | Software initialization failed, usually a hardware problem; cycle power. |
| E70 | Memory module error | The plug-in memory module is bad or not seated. |
| E72 | Drive temperature too high | Inverter thermal switch tripped: failed fan, high cabinet ambient or excessive duty cycle. |
| E74 | Peak current limit exceeded | Output current exceeded the drive's peak rating. |
| E76 | Blank memory module | A blank memory module was inserted into the drive. |
| E91 | User watchdog timeout | The explicit-message watchdog expired. |
| E92 | Bad battery | The absolute-encoder battery is low or missing. |
| E93 | Acceleration out of capability | The commanded acceleration exceeds what the drive / motor can deliver. |
| E94 | Motor / feedback cable | Motor power or feedback cable fault detected. |
| E95 | Wrong indexing mode | An index was commanded in a mode that does not support it. |
Where the manual's only remedy for a code is to replace the unit or module, the code is pointing at a hardware fault inside that part. Those are the faults NJT Automation repairs at component level, so a repair quote is usually the first thing to check before buying a replacement.
Source: Rockwell Automation publication 2097-UM001, Kinetix 300 EtherNet/IP Indexing Servo Drive User Manual. Codes are listed as documented; fault behaviour can vary by firmware revision, so confirm against the manual for your unit's series.
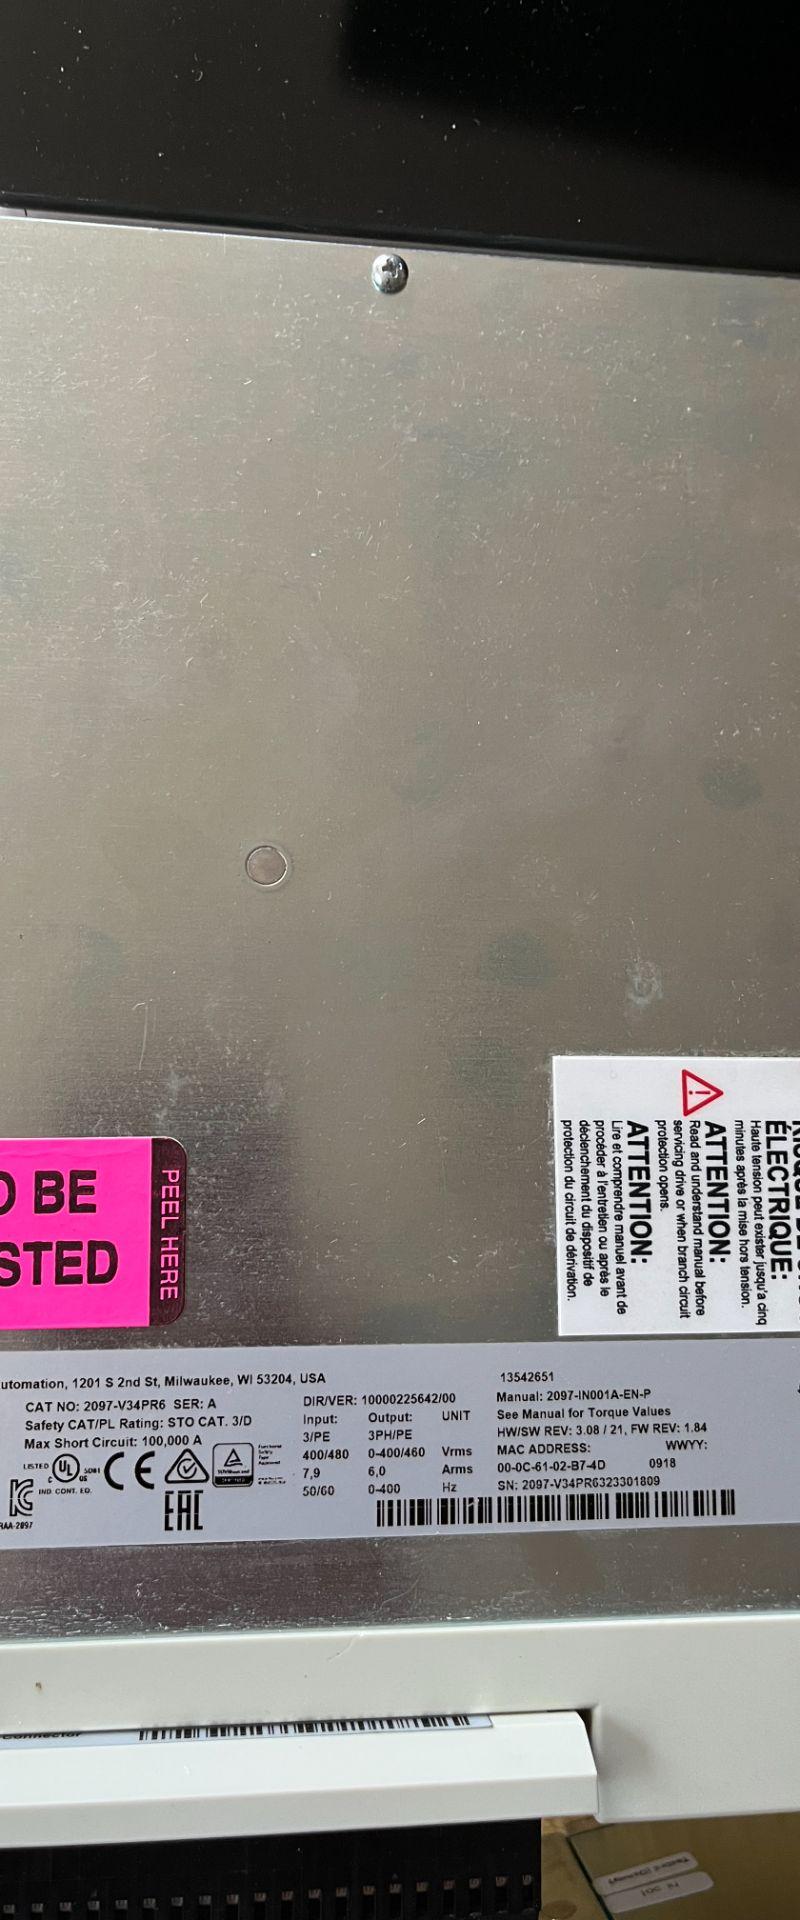
Photos by NJT Automation; test videos from NJT or network repair technicians.
Still have questions?
Find answers to shipping, warranties, repairs, and more.